01
Data Curation
Pull episodes from your fleet, then use embedding search to surface the edge cases that close distribution gaps.
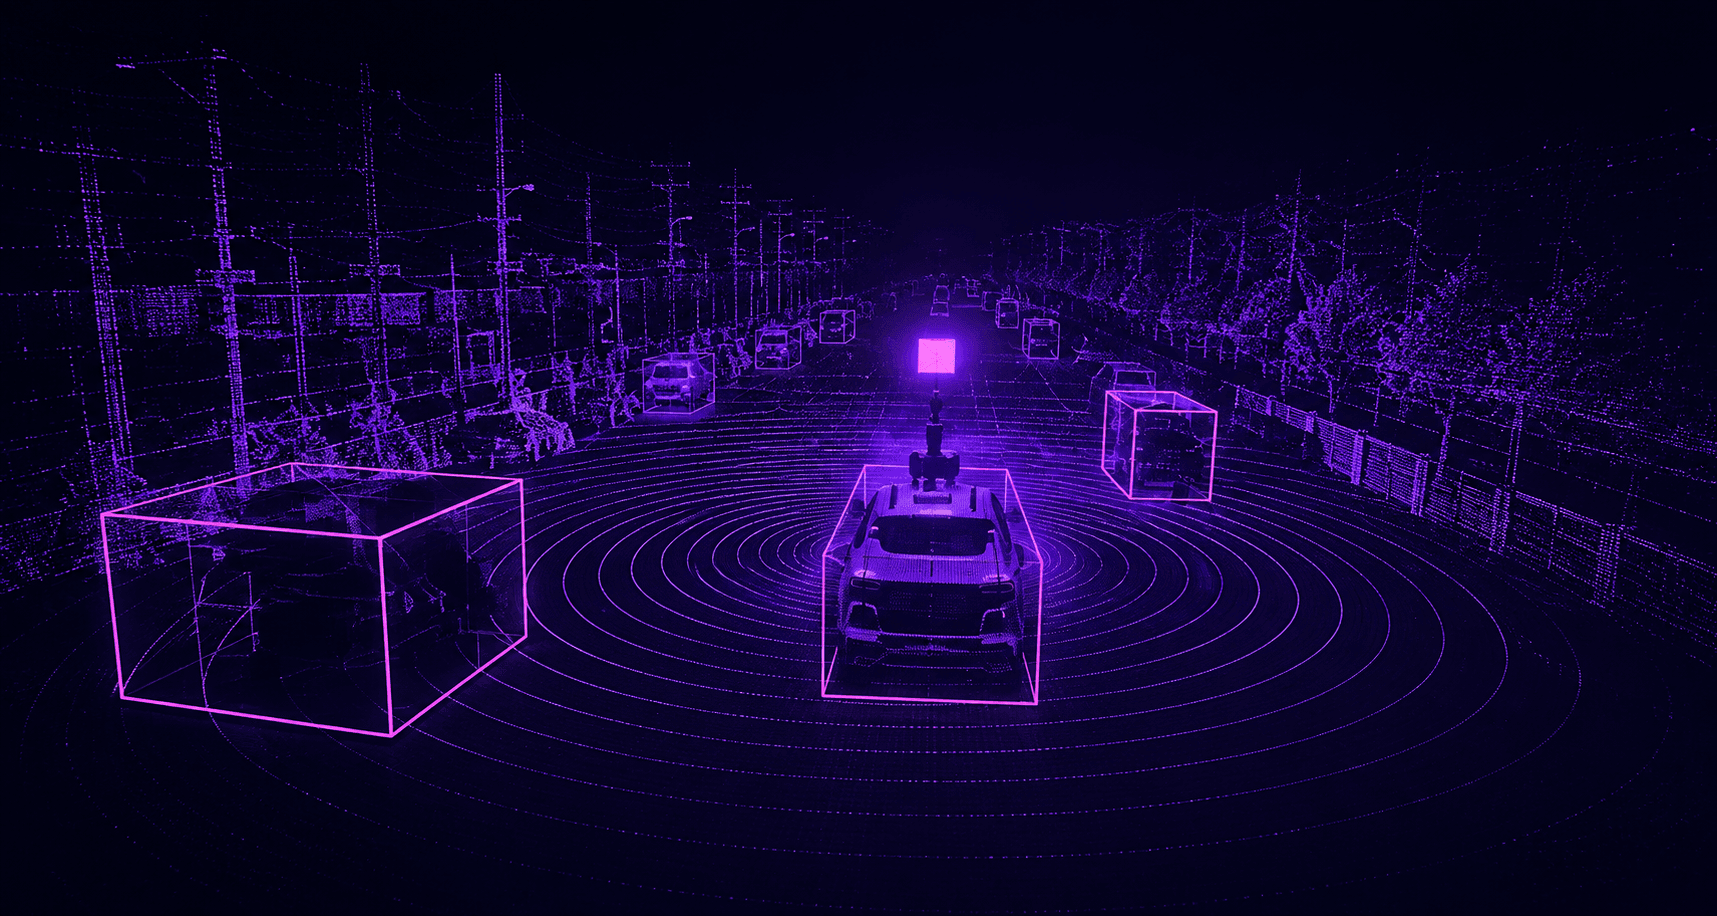
Sentious turns raw robot logs into training-ready data: native ROS 2 and MCAP parsing, zero-copy WebGPU review of every sensor stream, and export straight to LeRobot v3.0.
02 / Platform
An agentic workflow, reinforced with human feedback — one system from the first raw episode to the model you ship.
Pull episodes from your fleet, then use embedding search to surface the edge cases that close distribution gaps.
Video, LiDAR, audio and fused sensor streams in one workspace — with label lineage and production-grade quality control built in.
Benchmark and stress-test policies against the scenarios that matter, long before they meet the real world.
Turn evaluation insight into measurable gains, then scale what works across every robot, task and dataset.
03 / Pipeline
Every episode moves through one pipeline — parsed natively, rendered on the GPU, labeled with a model in the loop, and exported in the format your policy trains on.
Cameras, LiDAR, IMU, joint states and audio — straight from the robot or the fleet.
→ .mcap · .bag · video
Topics decoded natively and time-aligned to a single clock. No conversion step, no lossy export.
→ time-aligned topics
Every stream rendered straight from GPU memory, so multi-sensor episodes play back at full fidelity.
→ GPU buffers, no copy
Models propose; expert reviewers confirm, correct and teach. Every label keeps its lineage.
→ labels + provenance
Episodes packaged in the format your policy trains on — ready for the next run.
→ Parquet + MP4 episodes
04 / Agentic Feedback & Recommendations
Sentious agents analyze annotation work as it happens, incorporate reviewer feedback, turn outcomes into insight, recommend improvements and suggest labels automatically — with humans always in control.
Split this action: align → grasp
Segment · 00:11.4
Object is likely a mug
Confidence 88%
Add contact event at 00:12.9
Event